One person.
One workbench.
Hi, I’m Matt. Volary Dynamics is me.
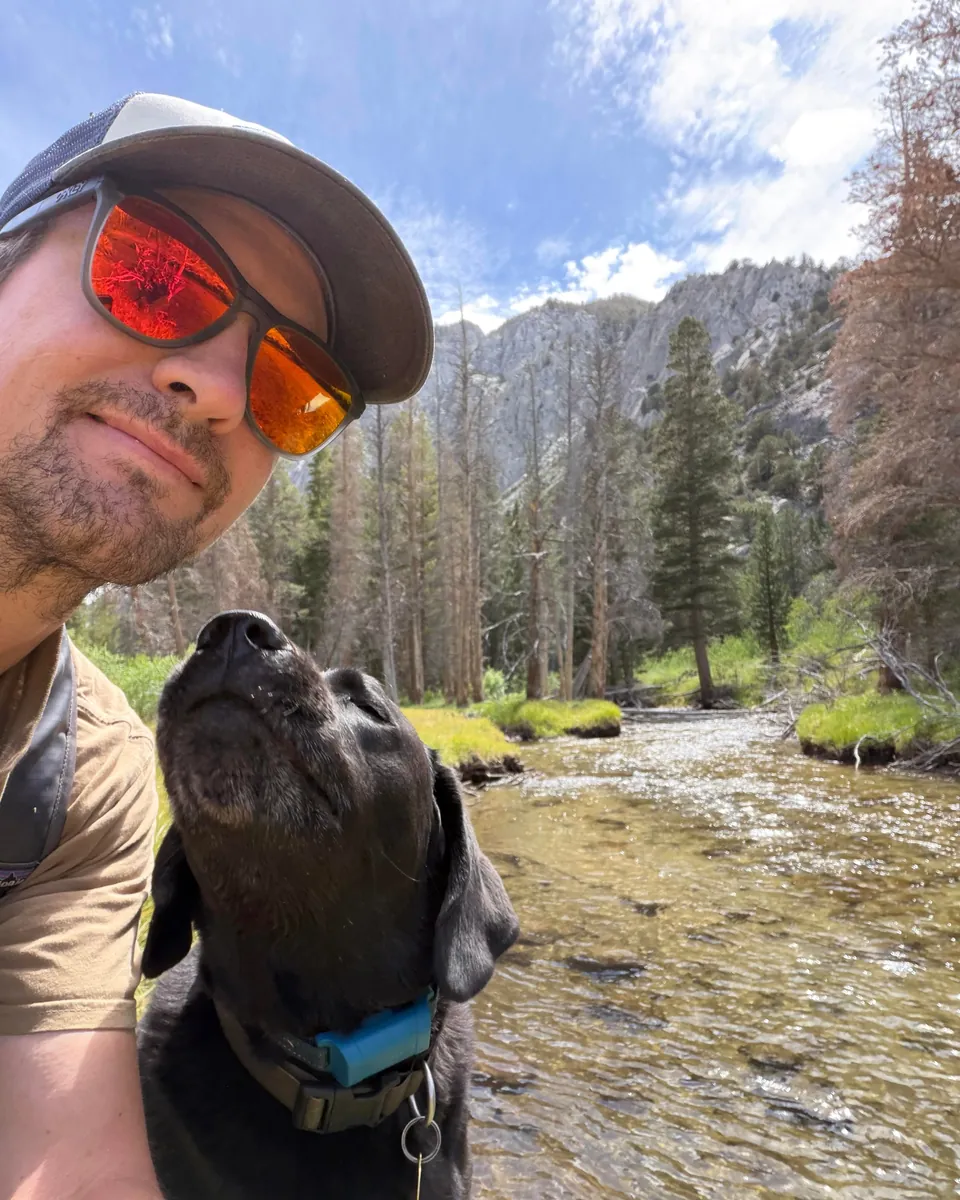
Not a conglomerate, not a startup with investors, not really much at all. I picked the hardware, built the firmware and the web console, drew every screen, tested it against the real traffic over my house, and put this website together. If something on the board makes you smile, that was me cursing over it at the workbench late at night, beer in hand.
I work in the aerospace and defense industry, and I’ve been hooked on anything that flies for as long as I can remember. Yes, I’m a nerd about it. I wanted something on my desk that showed what was flying around me as real-time as possible without building a full-on antenna in the backyard (someday). Nothing out there did it the way I wanted, and nothing did it on e-ink. So I built one for myself.
Somewhere along the way it got pretty rad, and I started to introduce it to friends who also enjoyed it. That’s the whole reason it’s here. This isn’t about making a pile of money. It’s a labor of love, and I think anyone who looks up every time a plane goes over and wonders ‘where’s that one headed’ will love it as much as I do.
When I’m not tinkering with electronics, I’m out in the Sierra Nevada backcountry with my wife and our dogs, backpacking or fly fishing somewhere well past the end of the cell signal.
Thanks for stopping by. — Matt
Version 1
Before the e-ink board, there was this: an ESP32 on a breadboard and a couple of LCDs I had lying around. A character display for the callsign, altitude and distance, a little round screen running a radar sweep, an LED matrix, and a rat’s nest of jumper wires.
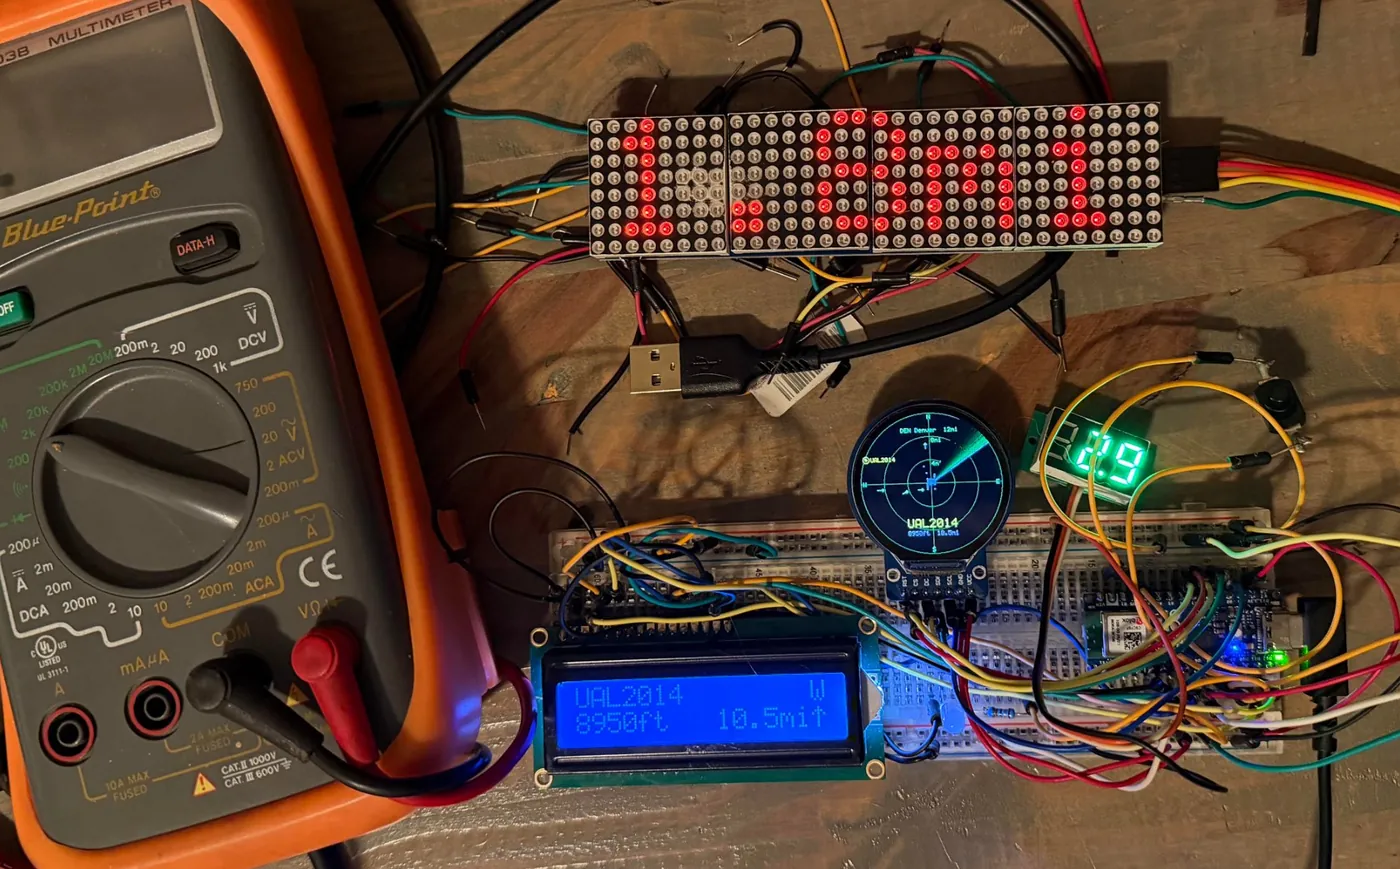
V1 · ESP32 on a breadboard · tracking UAL2014
Pre-production
And this is where it stands today: the pre-production board on my desk. Same 5.79″ e-ink panel, knob and two keys, running the firmware and web console you see on this site, tracking real air traffic.
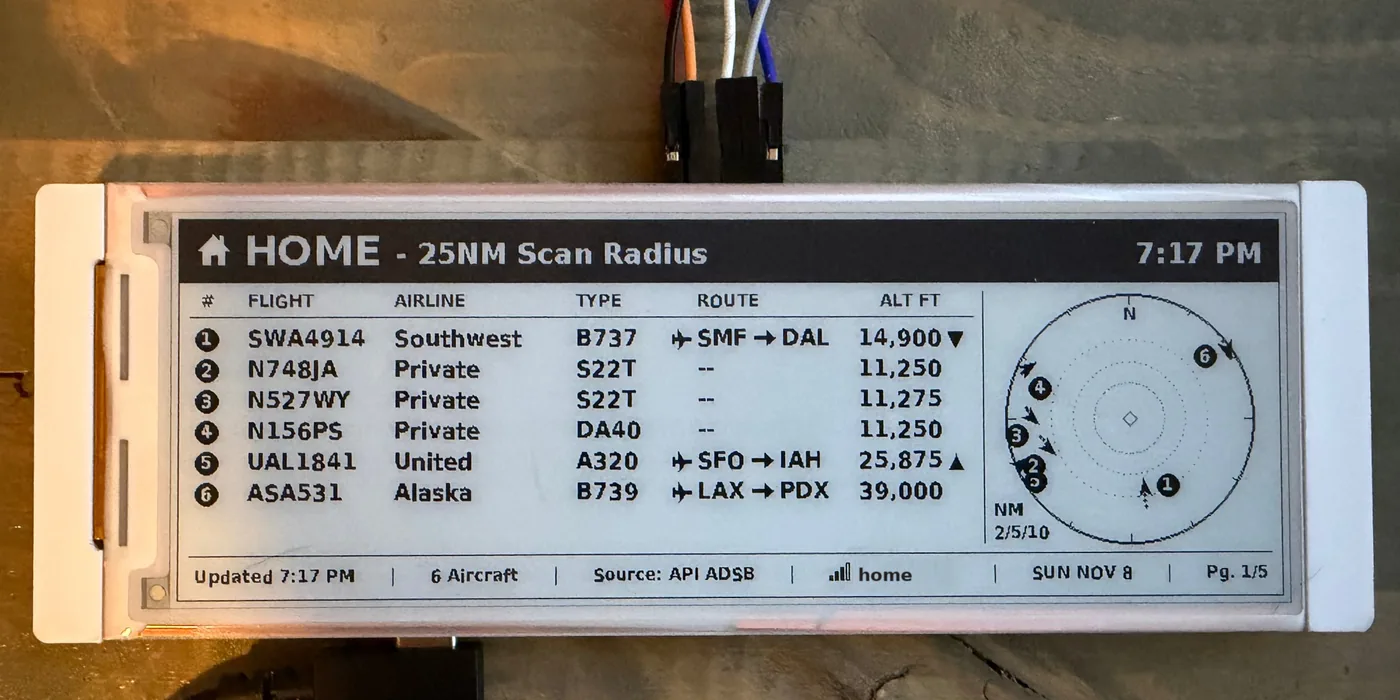
Pre-production · live traffic, 25 NM around my home